SELECTED PROJECTS

From pixels to places.

Building reconstruction pipelines around real capture conditions, from online aerial mapping to geometry completion.

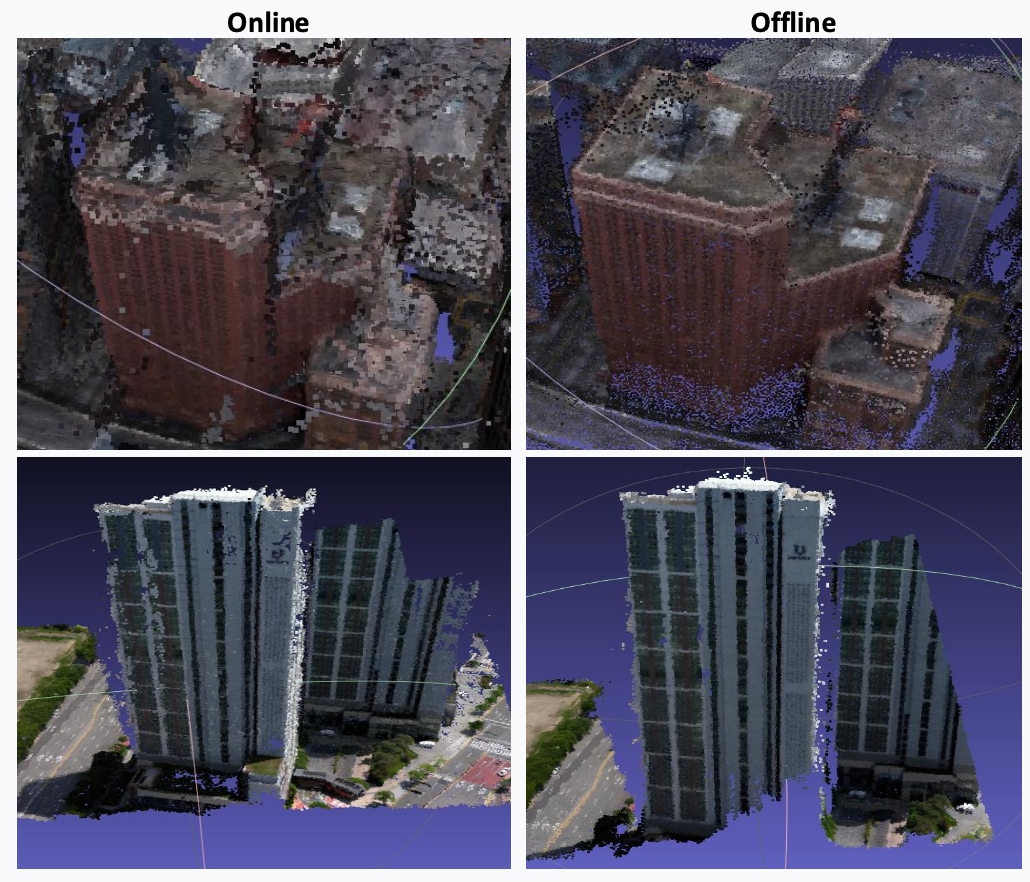
Drone imagery and reconstructed scene from the online and offline mapping project

Mobility One Inc. · Oct. 2024 – Apr. 2025

From drone imagery to a 3D map.

SLAM / Multi-View Stereo / Gaussian Splatting

Online/Offline Real-Time 3D Reconstruction Using Drone Imagery

problem
Reconstruct aerial scenes while balancing online processing and offline geometric quality.
approach
Combine SLAM camera tracking with multi-view stereo in an online/offline reconstruction pipeline.
contribution
Adaptive keyframe selection, hierarchical bundle adjustment, and loop closure for pose drift correction.
result
Completed delivery to Mobility One and secured a follow-up project.
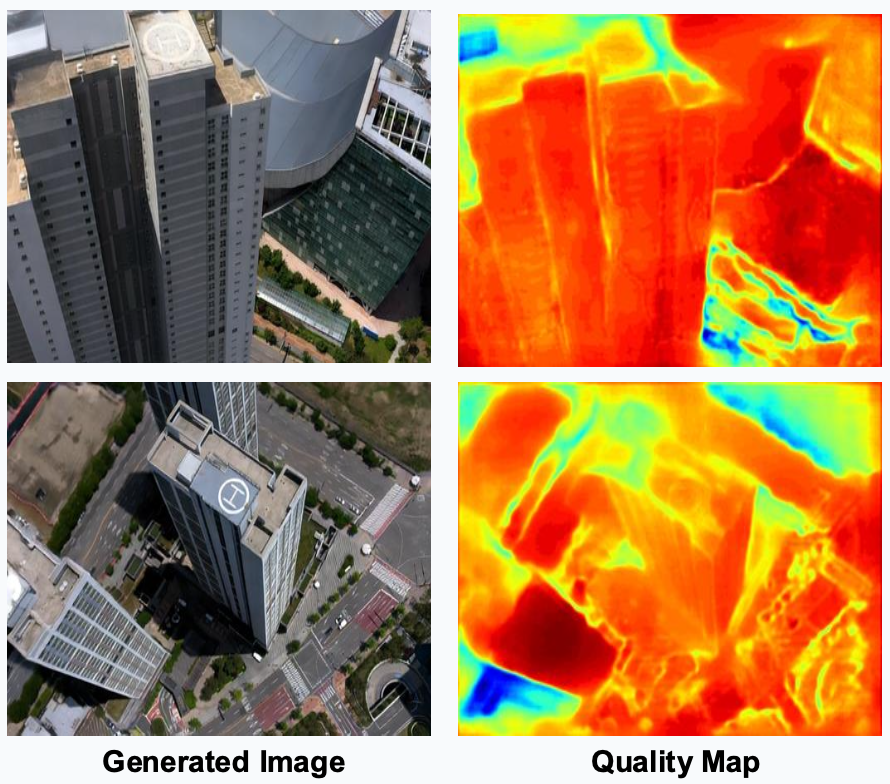
Diffusion-assisted completion pipeline for drone-based 3D reconstruction

Mobility One Inc. · Jun. 2025 – Dec. 2025

Reconstructing what the camera missed.

COLMAP / OpenMVS / Diffusion

3D Reconstruction with Diffusion-based Inpainting

problem
Sparse drone viewpoints leave incomplete regions in reconstructed 3D models.
approach
Use COLMAP and OpenMVS with diffusion-based image interpolation and inpainting.
contribution
A geometric constraint filter checks generated imagery for consistency before reconstruction.
result
Reconstructed missing mesh regions without additional image capture.

EARLIER WORK

Applied computer vision.

Mar. 2023 – Apr. 2023

Daeduck Electronics

Multi-focus (top/bottom) image defect detection proof of concept.

May 2023 – Dec. 2023

AI Voucher Project

Defect object detection model and equipment integration through a C++ SDK.

Apr. 2023 – Jun. 2023

Daeduck Electronics

Multi-angle image defect detection proof of concept.

Mar. 2023 – Dec. 2023

Seobaujeok

High-resolution cosmetic container defect inspection.

LET’S CONNECT

Better geometry.
New perspectives.

For research discussions and collaborations in 3D vision.